Of all the vehicle tech that underpins autonomous driving and advanced vehicle testing, positioning is among the most fundamental. A self-driving shuttle, an automated logistics vehicle or a test car running a validation route needs to know where it is, continuously and accurately. Satellite navigation provides that in open sky. But vehicles do not only operate in open sky, and the moment they enter a tunnel, an underground car park or a street lined with tall buildings, conventional GNSS positioning degrades or disappears altogether.
The GNSS gap
Global navigation satellite systems rely on receiving signals from multiple satellites. Anything that blocks or reflects those signals, from concrete roofs to glass-fronted buildings, can cause position errors or total loss of fix. For consumer navigation, this is an inconvenience. For autonomous vehicle development and vehicle testing, it is a serious problem.
Test engineers lose data in exactly the places that matter most. Autonomous systems need independent ground truth to validate how their own localisation behaves when conditions become difficult. And fleet operators running vehicles through tunnels and covered depots need continuity to track assets reliably.
How untethered dead reckoning works
Dead reckoning estimates position by starting from a known point and integrating measured motion over time. Modern implementations fuse satellite data with inertial sensors, accelerometers and gyroscopes, so that when satellite signals are lost, the inertial data continues to update the position estimate.
Traditional dead reckoning systems are tethered. They need inputs from the vehicle, such as wheel speed or steering angle, typically read from the vehicle’s own CAN network. That creates integration work and compatibility problems, particularly on prototype vehicles or when moving equipment between different platforms.
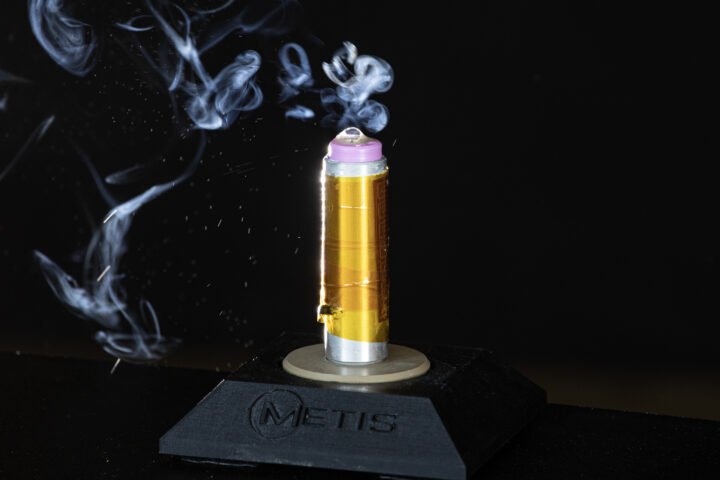
Untethered dead reckoning removes that dependency. Metis Engineering’s R&D UDR GPS CAN Sensor contains its own inertial sensors and needs no external inputs. When satellite signals are available, it provides standard positioning. When they are lost, it continues to estimate position, speed and heading from its internal sensors. When signals return, it recalibrates automatically. The result is a continuous position record from one self-contained unit.
Proven in real-world conditions
Metis Engineering demonstrated this in a test that drove a vehicle into an underground car park while logging data from both the UDR sensor and its standard 50Hz GPS CAN Sensor. At the car park entrance, the standard receiver lost its fix completely. The UDR sensor, using its inertial measurements, continued to track the vehicle’s route through the structure.
The same test illustrated why both technologies have a place. In open outdoor conditions where signals will not be lost, and especially where the vehicle may experience side slip or irregular movement, the high update rate of the 50Hz sensor gives the most accurate trajectory.
Matching update rate to the task
Update rate is a key specification in any positioning vehicle tech. The R&D UDR GPS CAN Sensor outputs latitude, longitude, altitude, course over ground and speed at up to 20 Hz, a position update every 50 milliseconds. That is sufficient to capture vehicle dynamics during normal manoeuvres and to analyse system behaviour during critical events, while keeping data volumes manageable.
For high-speed dynamics work, such as circuit testing, proving ground validation and motorsport, the R&D 50Hz GPS CAN Sensor captures position, velocity and trajectory up to 50 times per second, with 40 Hz recommended for the best positional performance. Metis used this capability in its project to determine rally car side slip, combining high-rate positioning with other vehicle data.
Integration that keeps pace with test programmes
Both sensors output data over CAN bus with a configurable interface, allowing them to attach to almost any vehicle or logger network. A DBC file enables the navigation data to be decoded in standard analysis tools. Wide input voltage ranges and compact dimensions make installation simple across passenger cars, commercial vehicles, robots, drones and autonomous pods. For bench set-up and quick installation, the Metis R&D Development Kit provides power and CAN connectivity.
Because the positioning data sits on the same CAN network as other vehicle signals, it can be logged with synchronised timestamps. Engineers can then correlate position with braking, steering, powertrain or ADAS events without complex post-processing.
What engineers should specify
When choosing positioning vehicle tech for a test or autonomy programme, three questions settle most decisions. Will the vehicle spend time where satellite signals are blocked or reflected? If so, untethered dead reckoning is the baseline requirement. Does the work involve high-speed dynamics, side slip or rapid direction changes in open sky? Then update rate matters most, and a 50 Hz receiver earns its place. Finally, how much integration effort can the programme absorb? A sensor that needs no wheel speed input and arrives with a DBC file can be moved between prototype vehicles in an afternoon, which keeps test schedules intact when vehicles, platforms and priorities change.
Building confidence in autonomy
Autonomous vehicles must demonstrate that they behave safely when conditions are imperfect. Validating how a system handles GNSS degradation, whether backup localisation modes activate correctly and whether safe operation continues in a tunnel requires independent reference data that does not itself fail in those conditions. Untethered dead reckoning provides that reference.
The wider sensing picture
Positioning is one piece of the vehicle tech puzzle. Metis Engineering’s CAN-based range also includes inertial sensors using accelerometers, gyroscopes and magnetometers, environmental sensors such as Air Wise for cabin air quality in autonomous pods, and battery safety sensors such as Cell Guard. All share the same approach to CAN integration, making it straightforward to build a comprehensive data picture on a single network.
To discuss positioning and sensing for autonomous or vehicle test programmes, contact Metis Engineering at info@metisengineering.com.